Overview
As a Robotics Mechanical Design Co-op at Medtronic, I worked on next-generation surgical robotics. Most of my work was building test fixtures and engineering tools that let the team evaluate designs earlier, before committing to a production design or waiting on formal analysis.
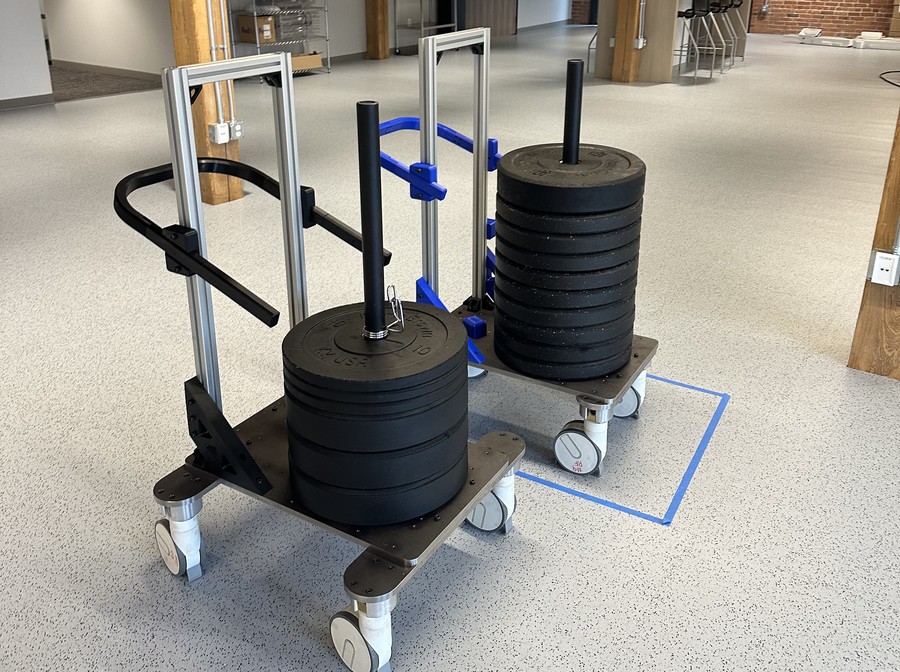
- Designed and built a configurable steel cart that simulates the mass and center of gravity of surgical robot arm carts for user studies.
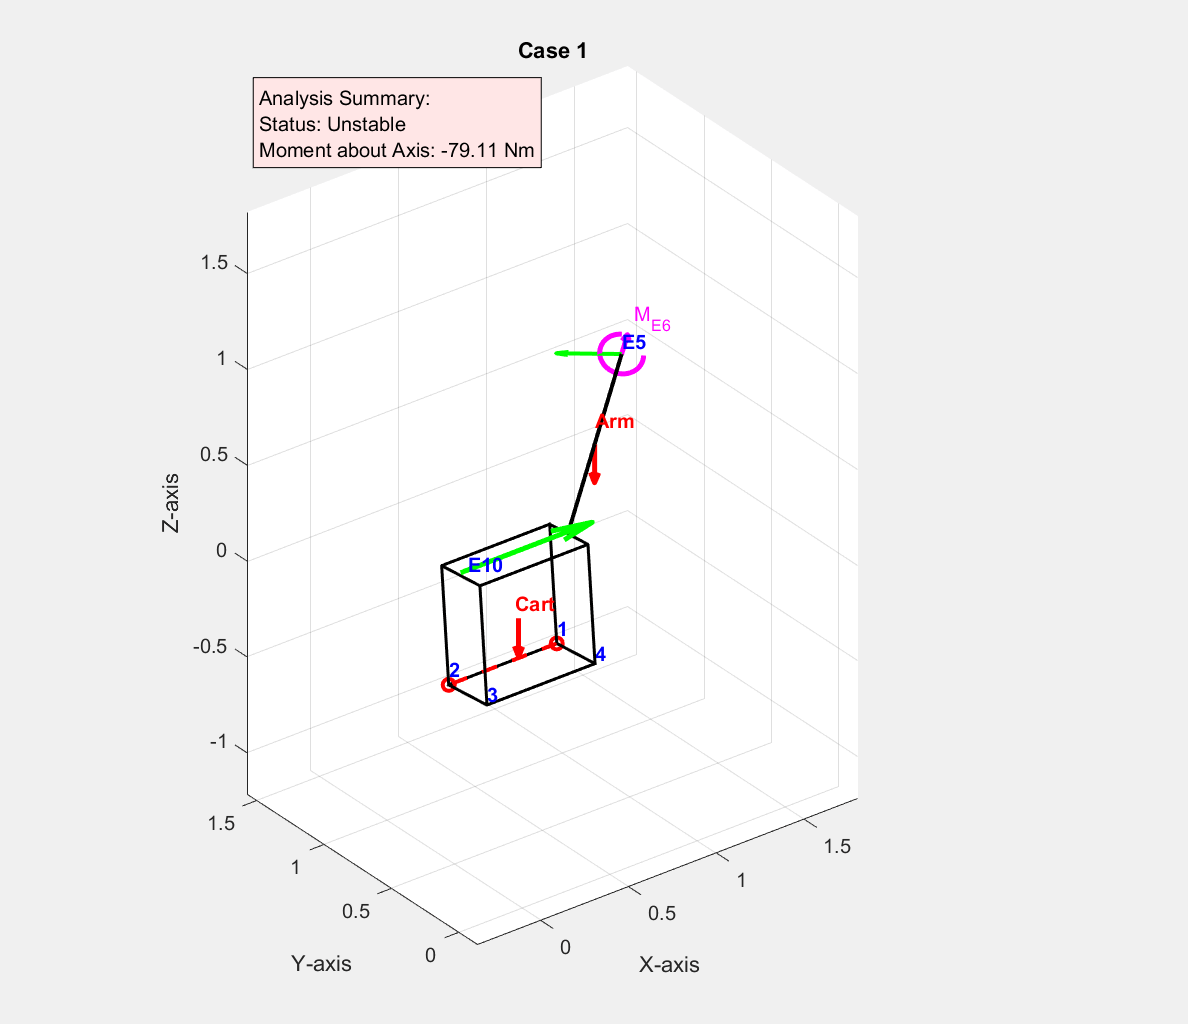
- Wrote a MATLAB tool that gives engineers instant IEC 60601 stability feedback, cutting a design iteration from days to minutes.
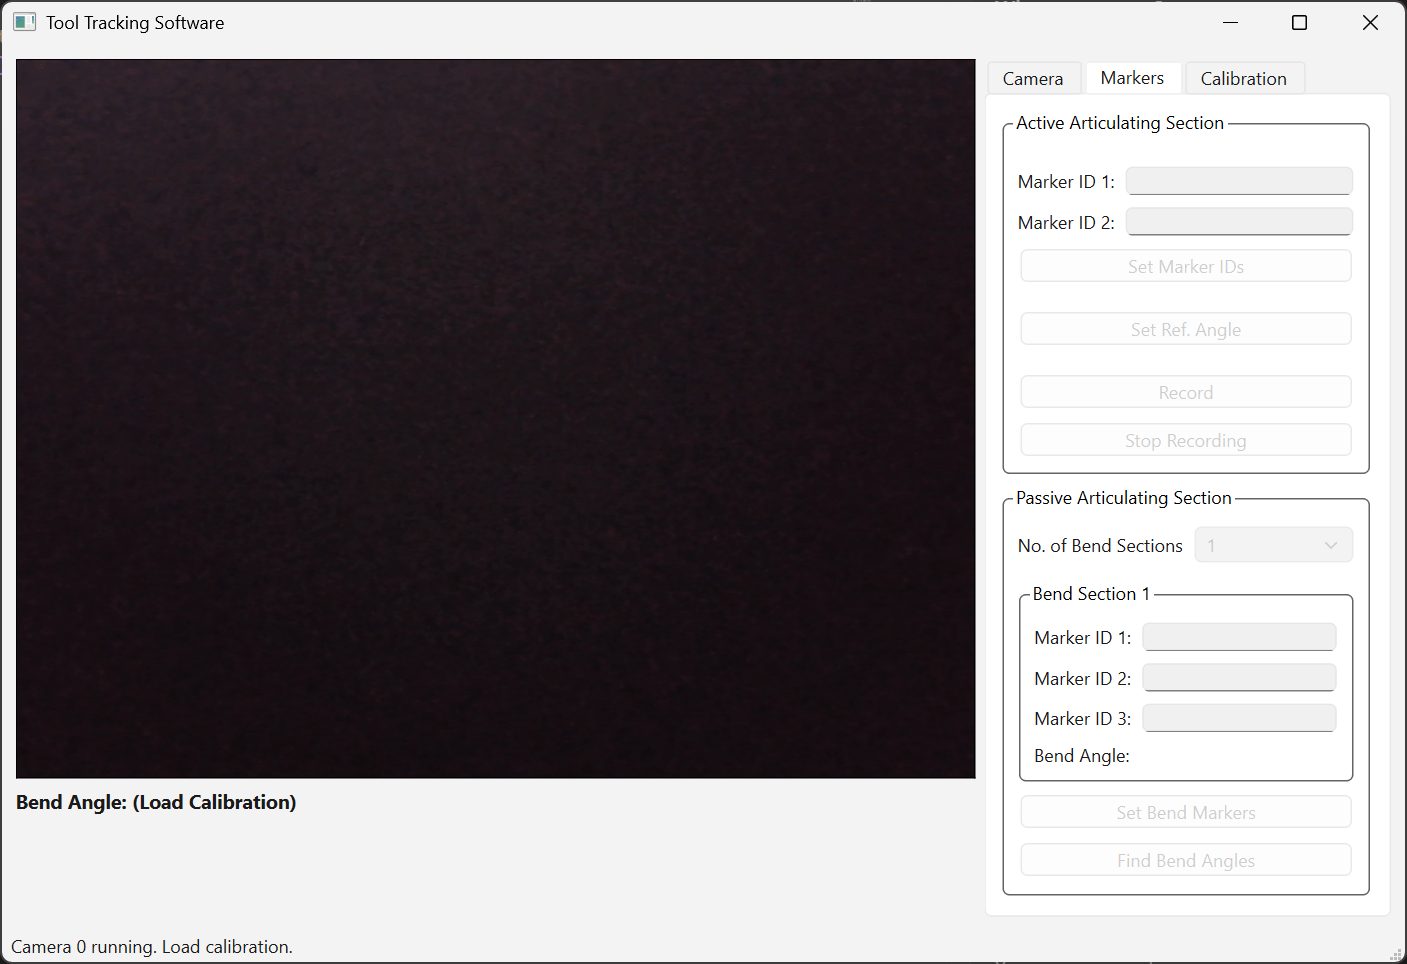
- Developed a computer-vision app that measures and logs bend angles in real time using ArUco markers.
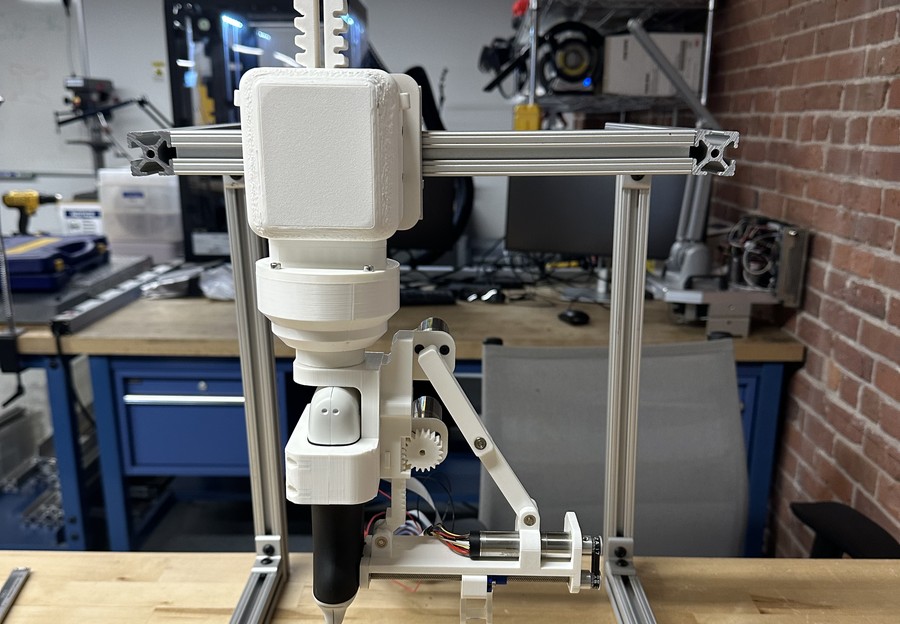
- Designed and prototyped a mechatronic fixture for precise, automated needle positioning.